Encoders
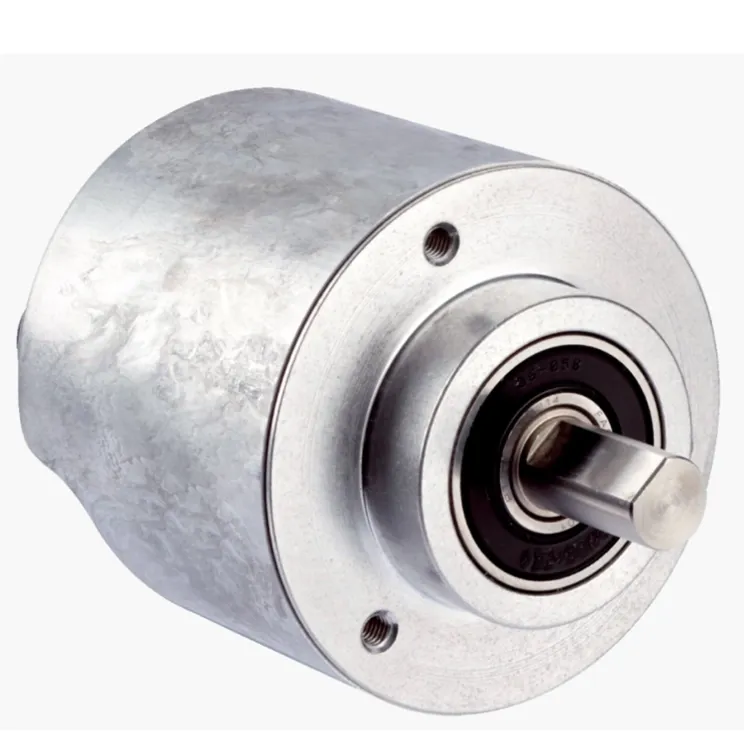
SICK AFS60A-S4NB262144 Sensor
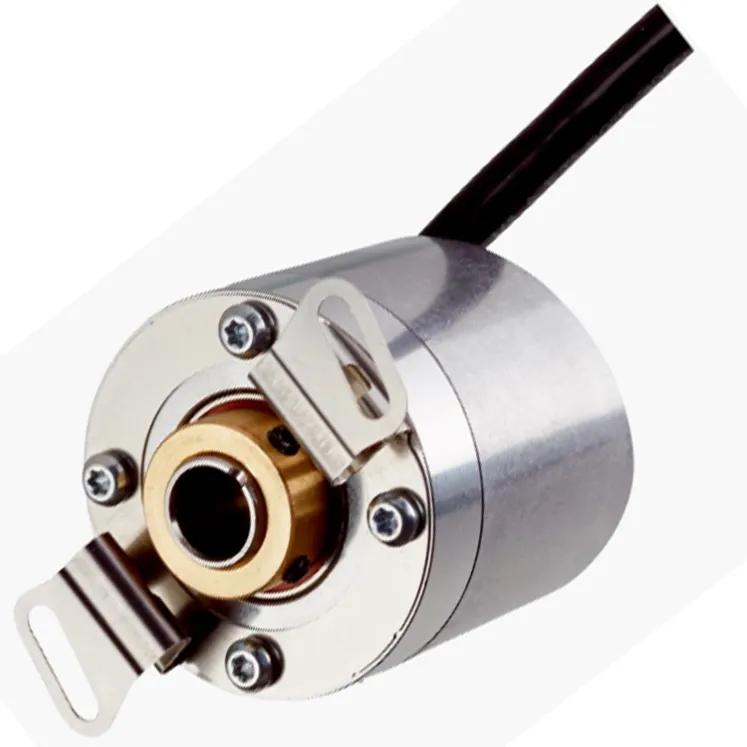
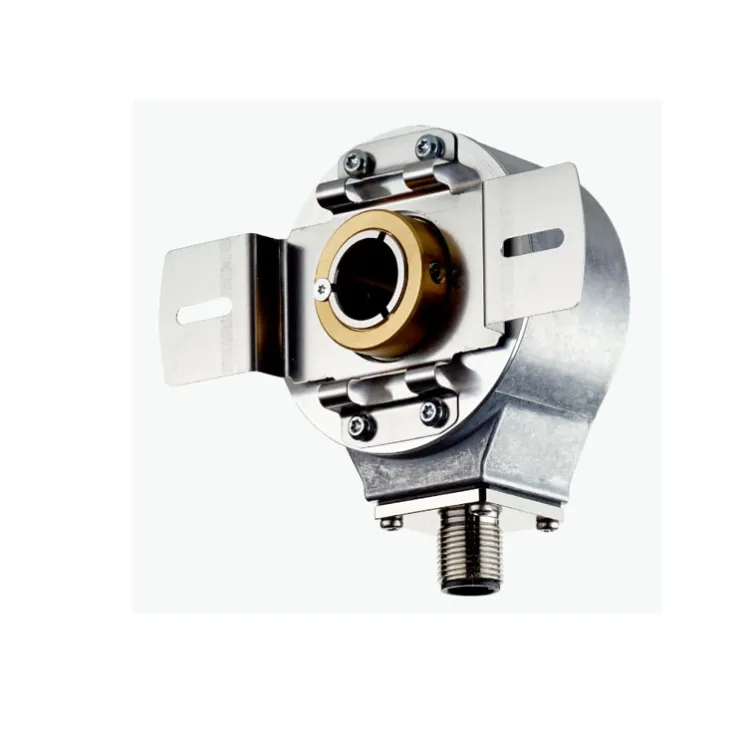
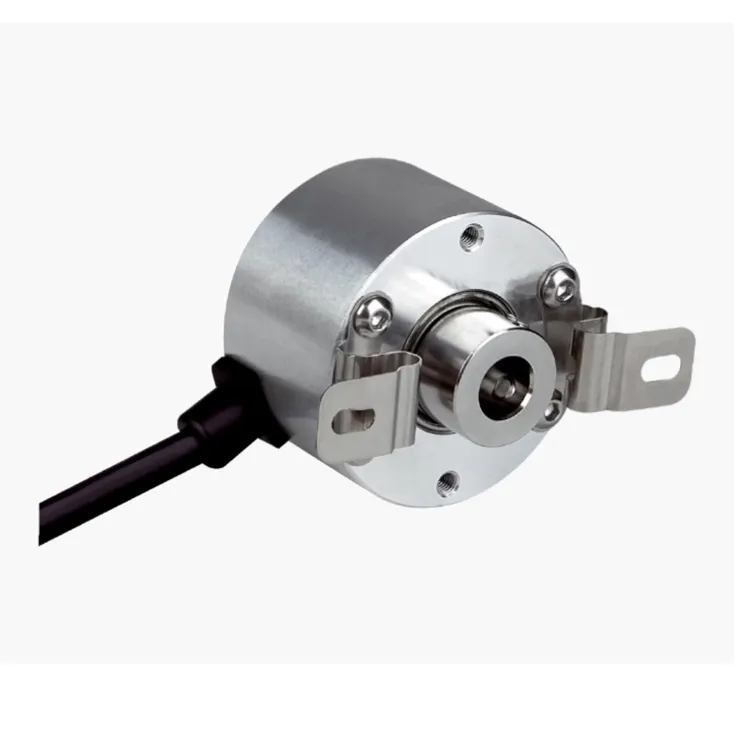
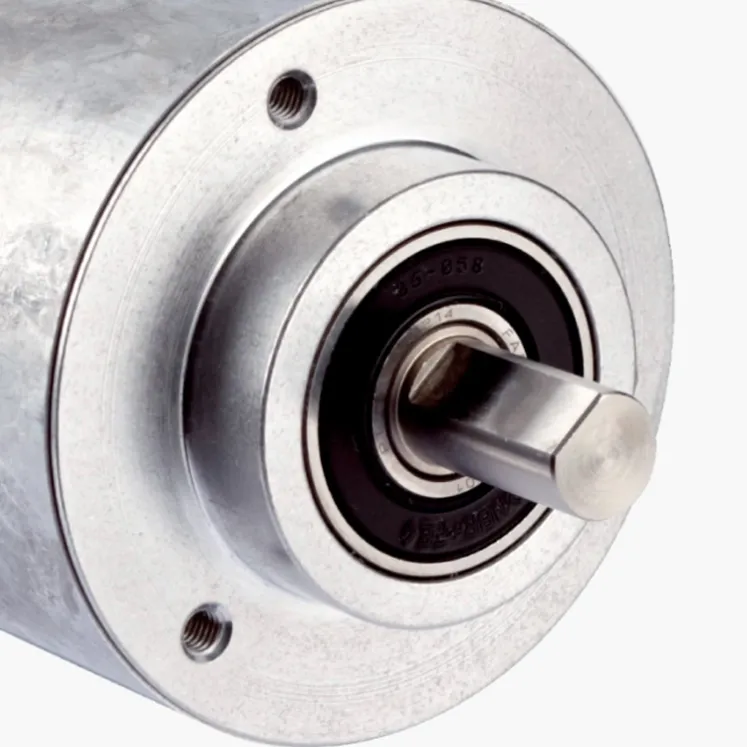
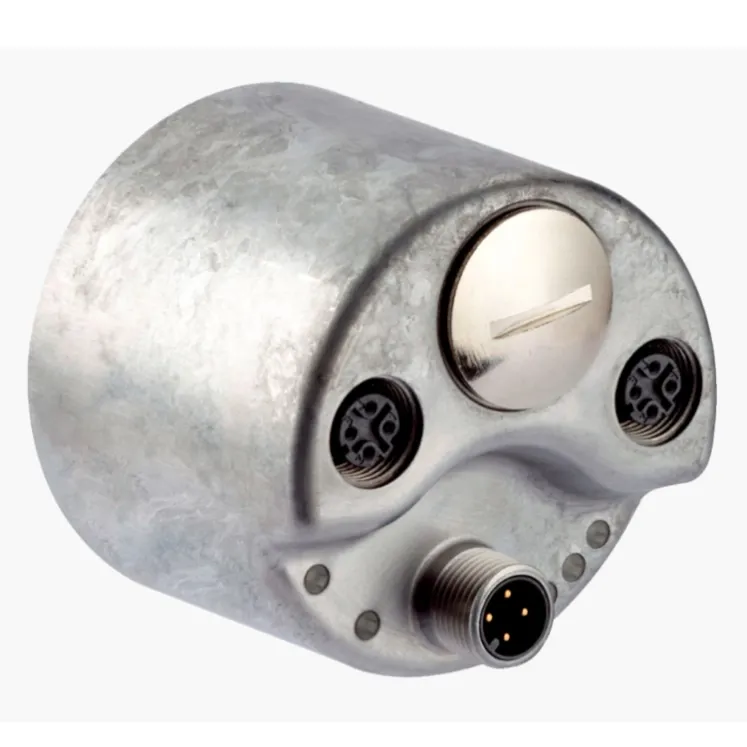
SICK AFS60A-S4NB262144 absolute single-turn encoder, part 1059050. 262144 positions per revolution for servo drives and motion control.
Overview
The SICK AFS60A-S4NB262144 (part number 1059050) is an absolute single-turn rotary encoder of the AFS60A family. It delivers an unambiguous position value for every shaft angle over one revolution, with 262144 positions per revolution as indicated by the order code, providing high-resolution feedback for servo drives and motion control.
How It Works
An optical code disc is read out at high resolution as the shaft rotates. Because each angle maps to a unique position value, the absolute encoder reports the correct shaft position immediately after power-up, without homing moves or reference runs. The position value is transmitted to the drive controller over the encoder interface.
Key Features
- Absolute position value, no reference run needed
- 262144 positions per revolution (order code)
- Part number 1059050
- High-resolution optical single-turn measurement
- Compact flange for motor and machine mounting
- Reliable feedback for closed-loop motion control
Typical Applications
- Motor feedback on servo drives and inverters
- Position feedback on rotary tables and indexing units
- Angular position measurement on material handling axes
- Feedback for robotics and assembly kinematics
- Positioning on packaging and printing machinery
Specifications
Attribute | Value |
|---|---|
Model | SICK AFS60A-S4NB262144 |
Part number | 1059050 |
Encoder type | Absolute single-turn rotary encoder |
Resolution per revolution | 262144 positions (order code) |
Installation and Setup Notes
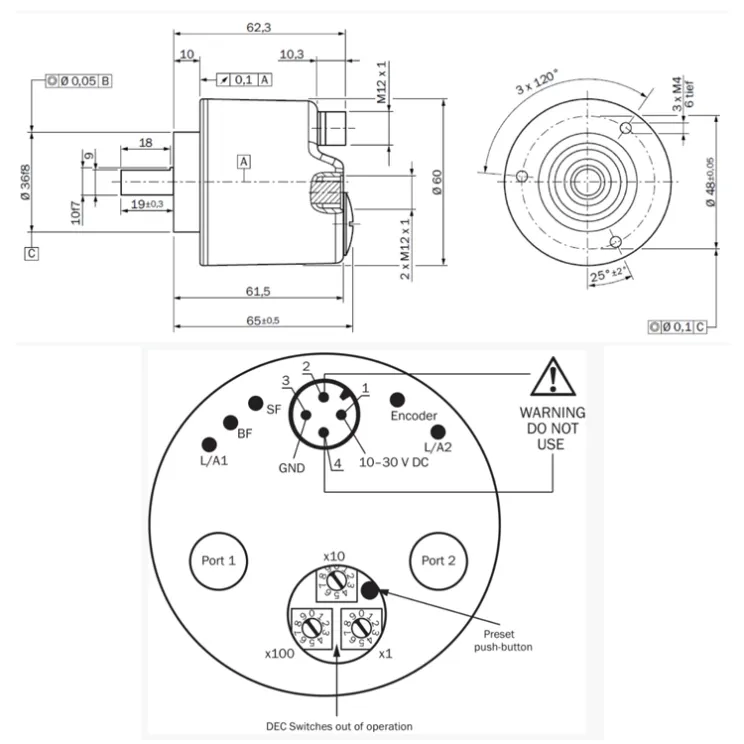
Couple the shaft with a torque bracket or flexible coupling to absorb alignment error, and observe the permitted shaft loads of the family. Connect the interface according to the drive manufacturer's wiring guidance and configure the drive to the encoder resolution. Verify the direction of rotation and position scaling after commissioning.
Frequently Asked Questions
Why choose an absolute encoder?
It reports the true shaft position immediately at power-up, eliminating homing cycles and improving machine availability.
What does S4NB262144 mean?
The suffix identifies interface type and the 262144-step resolution per revolution of this variant.
Can it replace an incremental encoder?
Where the drive supports absolute feedback, it removes homing and improves position integrity.
Related Encoders
For hollow-shaft feedback, see the SICK ARS60-ADA32768. For servo feedback with SinCos signal, see the SICK SRS50-HZA0-S21.